Carlos Veintimilla
Mechatronics engineer and Assistant Professor at ESPOL, working on hardware design, sensor integration, and autonomous systems. Co-directing EOD-AV, an initiative to build Ecuador’s first open-source multimodal dataset for autonomous navigation, while exploring robotics and UAV development for research applications.
About
I’m a mechatronics engineer from Guayaquil, Ecuador, with a B.Sc. from Tecnológico de Monterrey (2023). I currently work as an Assistant Professor at ESPOL University and as a research member of the CoRAL Lab.
My work focuses on hardware design, sensor integration, and applied engineering. I’m the co-director of the Ecuador Open Dataset for Autonomous Vehicles (EOD-AV), a research project developing Ecuador’s first open-source multimodal dataset for autonomous navigation. Our goal is to support research on autonomous vehicles in local urban environments and help establish a regional reference for this field.
I’m also exploring autonomous systems and UAV design and development for research applications. I enjoy working at the intersection of hardware, sensing, and intelligent systems, turning ideas into practical projects while continuing to learn and explore new technologies.
Research
Ecuador Open Dataset for Autonomous Vehicle
Ecuador’s First Open-Source Autonomous Vehicle Dataset, Aiming to Become a Regional Reference for Research and Innovation
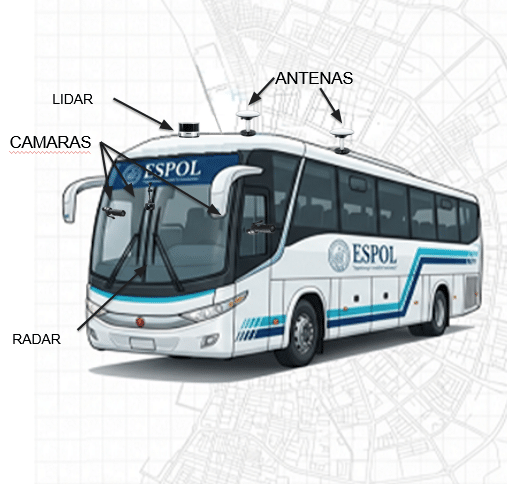
EOD-AV is a research initiative developing Latin America’s first open, urban, multimodal dataset for autonomous navigation in unstructured environments, starting in Guayaquil, Ecuador.
Most autonomous driving datasets are collected in highly structured urban environments, which may not adequately represent the complex and diverse conditions found in Latin American cities. EOD-AV aims to address this gap by collecting multimodal sensor data that reflects real-world driving conditions, supporting the development and evaluation of more robust autonomous navigation systems.
As co-director of the project, I contribute to coordinating this research initiative, bringing together multidisciplinary teams and supporting the development of an infrastructure for autonomous vehicle research in Ecuador, with the long-term goal of establishing a regional reference dataset.
Projects
Context – Definir Proyecto 1
Que hice en el proyecto, de qué trata
Objective
Cuál fue el fin
Contribution
Qué hice yo dentro del proyecto
Context – Teleoperated Robot
Que hice en el proyecto, de qué trata
Objective
Cuál fue el fin
Contribution
Qué hice yo dentro del proyecto
Context – Xiao ESP32-S3 Drone
Que hice en el proyecto, de qué trata
Objective
Cuál fue el fin
Contribution
Qué hice yo dentro del proyecto
Context – FSAE
Que hice en el proyecto, de qué trata
Objective
Cuál fue el fin
Contribution
Qué hice yo dentro del proyecto
Experience & Education
Tec de Monterrey
Bachelor of Applied Science in Mechatronics Engineering with Cyber-physical systems specialization.
Formula SAE Tec Racing
Aerodynamic Coordinator of the design of the vehicle.
January 2026 – Present
Co-Director of EOD-AV
Co-directing a multidisciplinary research initiative to develop Ecuador’s first open-source, multimodal dataset for autonomous navigation. Responsibilities include research coordination, sensor integration planning, team collaboration, and supporting data collection and dissemination to advance autonomous vehicle research in Ecuador and establish a regional reference for Latin America.
November 2024 – Present
Assistant Profesor – ESPOL University
Leading university lab sessions and practical training in advanced engineering fields, including Biomechatronics (Machine and Deep Learning), Flexible Manufacturing Systems using RobotStudio, and Applied Control Systems via Matlab.
January 2024 – June 2024
Assembly Supervisor – DACAR INDUSTRIES
Supervised assembly plant operations, leading technical teams, enforcing industrial safety protocols, and optimizing production schedules and quality assurance metrics to ensure the seamless execution of manufacturing and product quality plans
August 2020 – June 2023
Aerodynamics Coordinator – Formula SAE Tec Racing
Coordinated the design, development, and manufacturing of an electric Formula car, leading aerodynamics and manufacturing activities and collaborating with multidisciplinary teams. Designed and simulated aerodynamic profiles using Airfoil Tools and SolidWorks, gaining hands-on experience in additive manufacturing, and fiberglass fabrication. Contributed to the team’s 2nd-place finish in Engineering Design at FSAE México and recognition at Conecta Tec.